Summary
Ayrm is a custom 3-DOF robotic arm designed and built from the ground up, combining 3D-printed mechanical components, RobStride actuators, Raspberry Pi-based motion control, and a custom web interface. I designed the mechanical assemblies in SolidWorks, developed the electronics architecture, and built AyrmOS (with AI assistance) to control the arm over CAN.
Bill of Materials
| Category | Product | Quantity | Total Cost ($USD) |
| Actuators | Robstride Dynamics 05 | 3 | $345 |
| Actuators | MG90S Servo Motor | 1 | $5-10 |
| Compute | Raspberry Pi 5 (1GB) | 1 | $45 |
| USB-to-CAN Adapter | Robstride Dynamics CAN-to-USB Debugging Module | 1 | $30 |
| Plastic | Polymaker PETG Filament (Black, Yellow) | 2 | ~$40 |
| Fastening (Motor-To-Joint) | McMaster-Carr 91420A220 | 1 (Pack of 100) | $5 |
| Fastening (Motor-To-Base) | McMaster-Carr 92010A126 | 1 (Pack of 100) | $9 |
| Electronics | LM2596 DC-DC Buck Converter | 1 | $5-10 |
| Electronics | 5-way WAGO Connector | 1 (Pack of 10) | $15 |
| Electronics | 2-way WAGO Connector | 1 | $5 |
| Total | ~$509 |
Electronics Layout
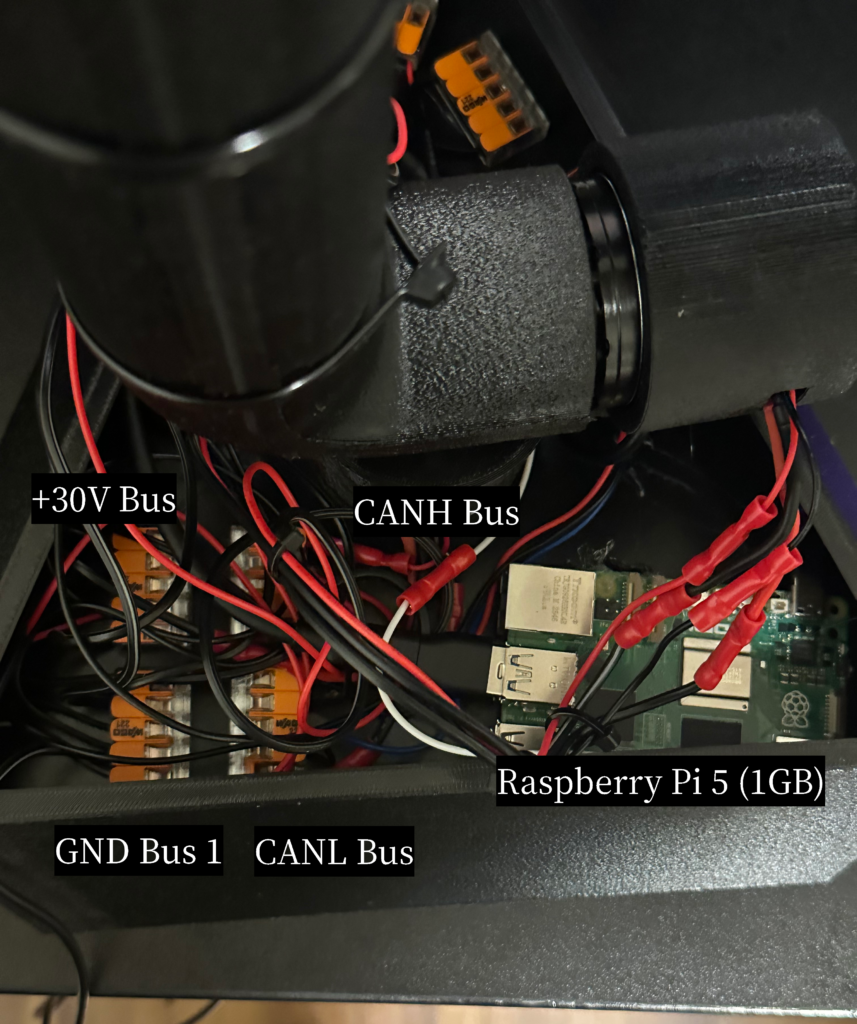
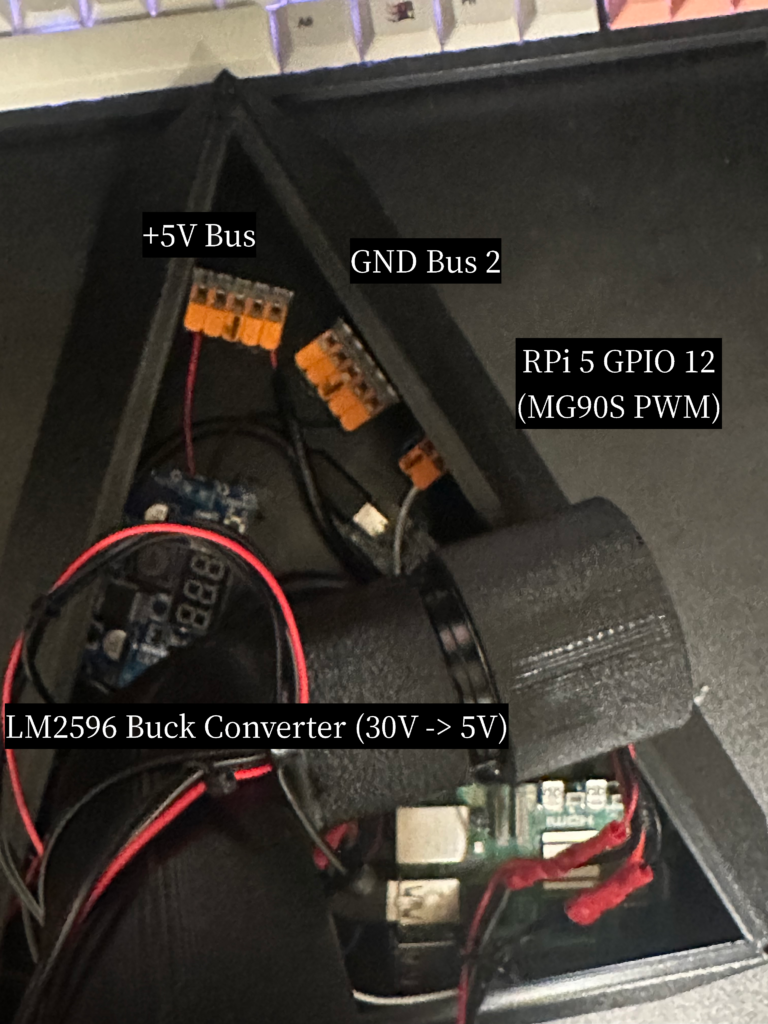
Testing
Test #1: 2 Joints (Base/Shoulder)
Manufacturing
All applicable parts were printed from Polymaker PETG for it’s toughness and resistance to snapping under load. They were printed on Dutch, my Sovol SV06 Plus 3D Printer. SLDPART files are available at the github links below, for free.
Base
Mountplate V2
Arm 1-1
Arm 1-2
Arm 2-1
Arm 2-2
Gripper Arm
Github Repositories
kermitine/Ayrm: open source 3-dof robotic arm
kermitine/AyrmOS: software and web app for controlling Ayrm robotic arm